Beehaw
  • Communities
  • Create Post
  • search
    Search
  • Login
  • Sign Up
cm0002 ( cm0002@lemdro.id )  to Technology@midwest.socialEnglish · 21 days ago

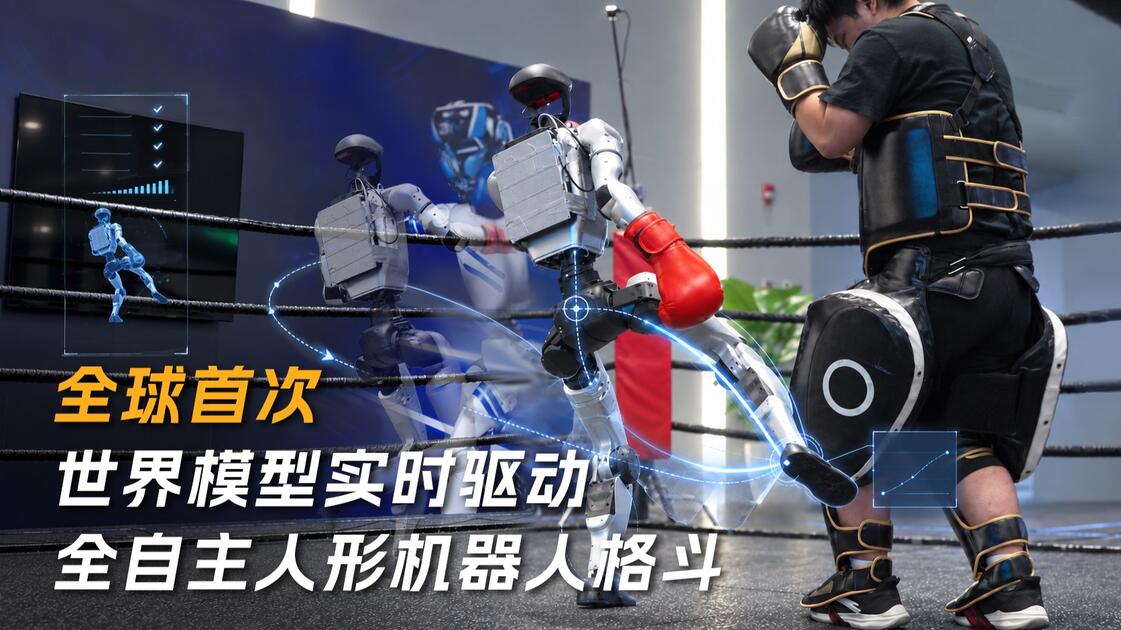
Fully Autonomous Humanoid Robot Fighting in Real Time

www.bilibili.com

external-link
message-square
1
link
fedilink
  • cross-posted to:
  • technology@lemmy.ml
1
external-link

Fully Autonomous Humanoid Robot Fighting in Real Time

www.bilibili.com

cm0002 ( cm0002@lemdro.id )  to Technology@midwest.socialEnglish · 21 days ago
message-square
1
link
fedilink
  • cross-posted to:
  • technology@lemmy.ml
宇树突破:全球首次世界模型实时驱动全自主人形机器人格斗_哔哩哔哩_bilibili
www.bilibili.com
external-link
UnifoLM-X2-1.0,突破世界-动作大模型瞬时规划、决策和动态交互执行等瓶颈,实现高动态、强交互、实时实现对未来预测和规划,实现人形机器人全自主搏击。验证了世界模型驱动的人形机器人大规模落地部署的基础可行性。, 视频播放量 455759、弹幕量 227、点赞数 10515、投硬币枚数 791、收藏人数 1338、转发人数 1260, 视频作者 Unitree宇树科技, 作者简介 智能体机器人行业领航者,90后们创立的公司,欢迎热爱科技的人一起推进人类科技。,相关视频:宇树发布:Dex5-S灵巧手 22自由度 真手1:1尺寸,GPT-6 Astra实测!原子弹瘫坐在我身上,仿佛看见椅子爆炸!,这是谁家的机器人嗖一下的就过去了???,宇树机器人实弹射击场景。,URKL机器人大赛,中日大战,众擎T800一台打十台川崎,宇树发布: GD800 载人重型机甲 10万元起,宇树人形机器人 日常训练,Seedance2.0生成的逆天羽毛球比赛,宇树机器人已经进化得不像机器人了!😂😂,宇树科技,史上最大泡沫?
alert-triangle
You must log in or # to comment.
  • Curious_Canid ( Curious_Canid@piefed.ca ) 
    link
    fedilink
    English
    arrow-up
    1
    ·
    21 days ago

    I agree.

Technology@midwest.social

technology@midwest.social

Subscribe from Remote Instance

Create a post
You are not logged in. However you can subscribe from another Fediverse account, for example Lemmy or Mastodon. To do this, paste the following into the search field of your instance: !technology@midwest.social

Post articles or questions about technology

Visibility: Public
globe

This community can be federated to other instances and be posted/commented in by their users.

  • 16 users / day
  • 69 users / week
  • 209 users / month
  • 712 users / 6 months
  • 128 local subscribers
  • 2.59K subscribers
  • 633 Posts
  • 577 Comments
  • Modlog
  • mods:
  • seahorse [Ohio] ( seahorse@midwest.social ) 
  • BE: 0.19.15
  • Modlog
  • Legal
  • Instances
  • Docs
  • Code